ADECS³ [Module-APS]
Automated Position System
The Automated Positioning System (APS) module is designed for a dock that physically transitions from one geographical location to another (for instance from a pier to a deep sink pocket). This is typically accomplished using winches with ropes or chains
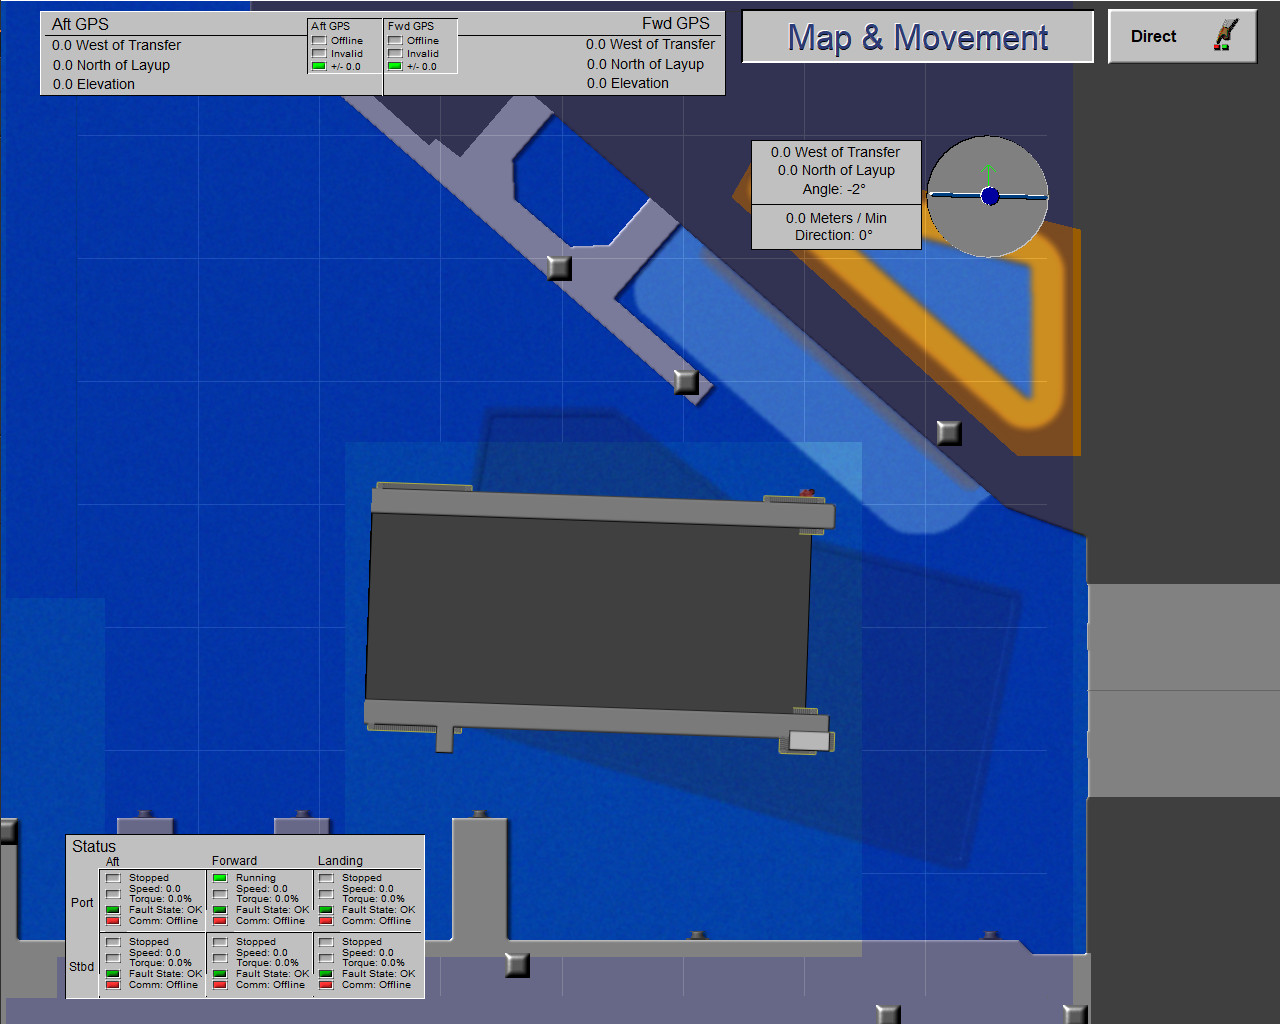
There are typically two parts to the APS: Location monitoring and Winch Control.
The Location Monitoring most commonly consists of two GPS receivers mounted on the dock which report the position of two corners. The associated geometry to determine the location and angle of the dock relative to the important geographical features (piers, dredged pockets, etc.).
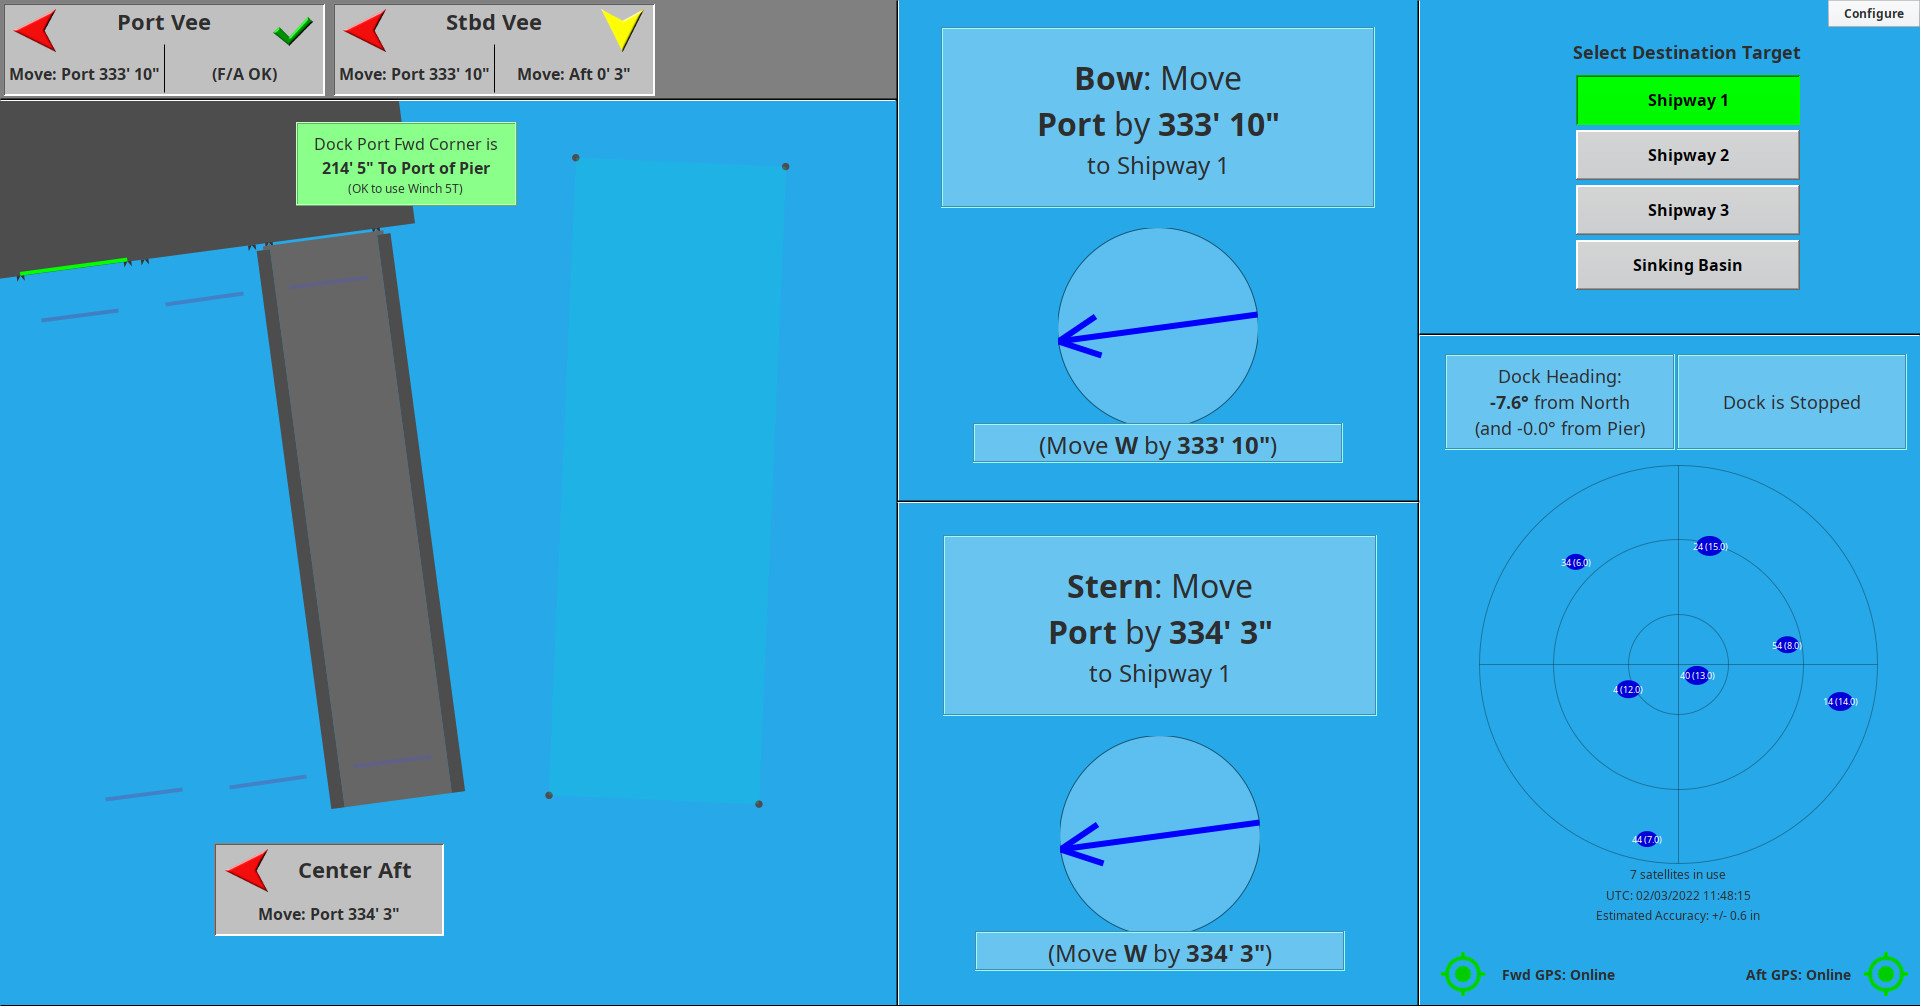
That information is displayed on a screen that shows the distances from the desired destination of from a known anchor point. The goal in presenting the information is to provide the operator with what is required to safely move the dock. This may include safety information, GPS status, winch status, etc. as desired by the customer.
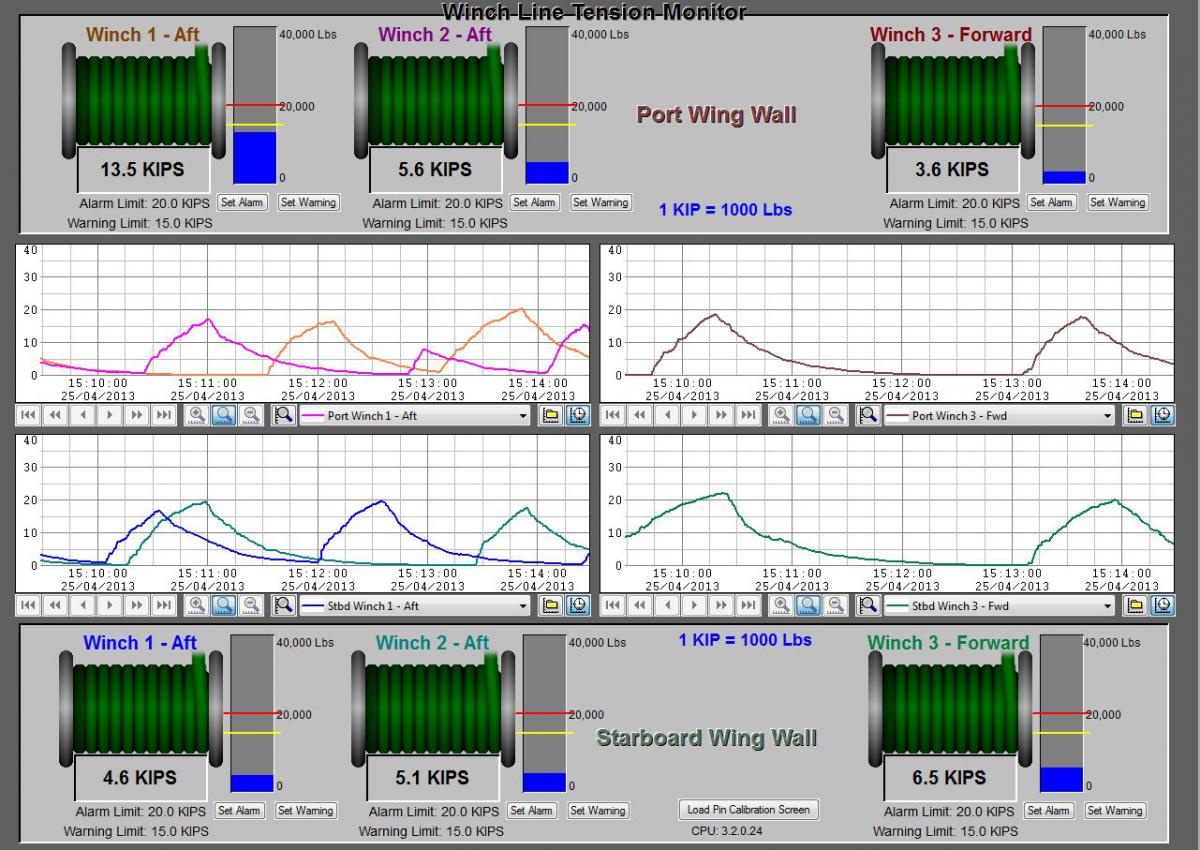
The Winch section consists of a means to individually monitor and/or control the various winches related to dock positioning. Like all information within the ADECS, the controls are presented in a manner that directly reflects the orientation of the dock with the orientation of the operator.
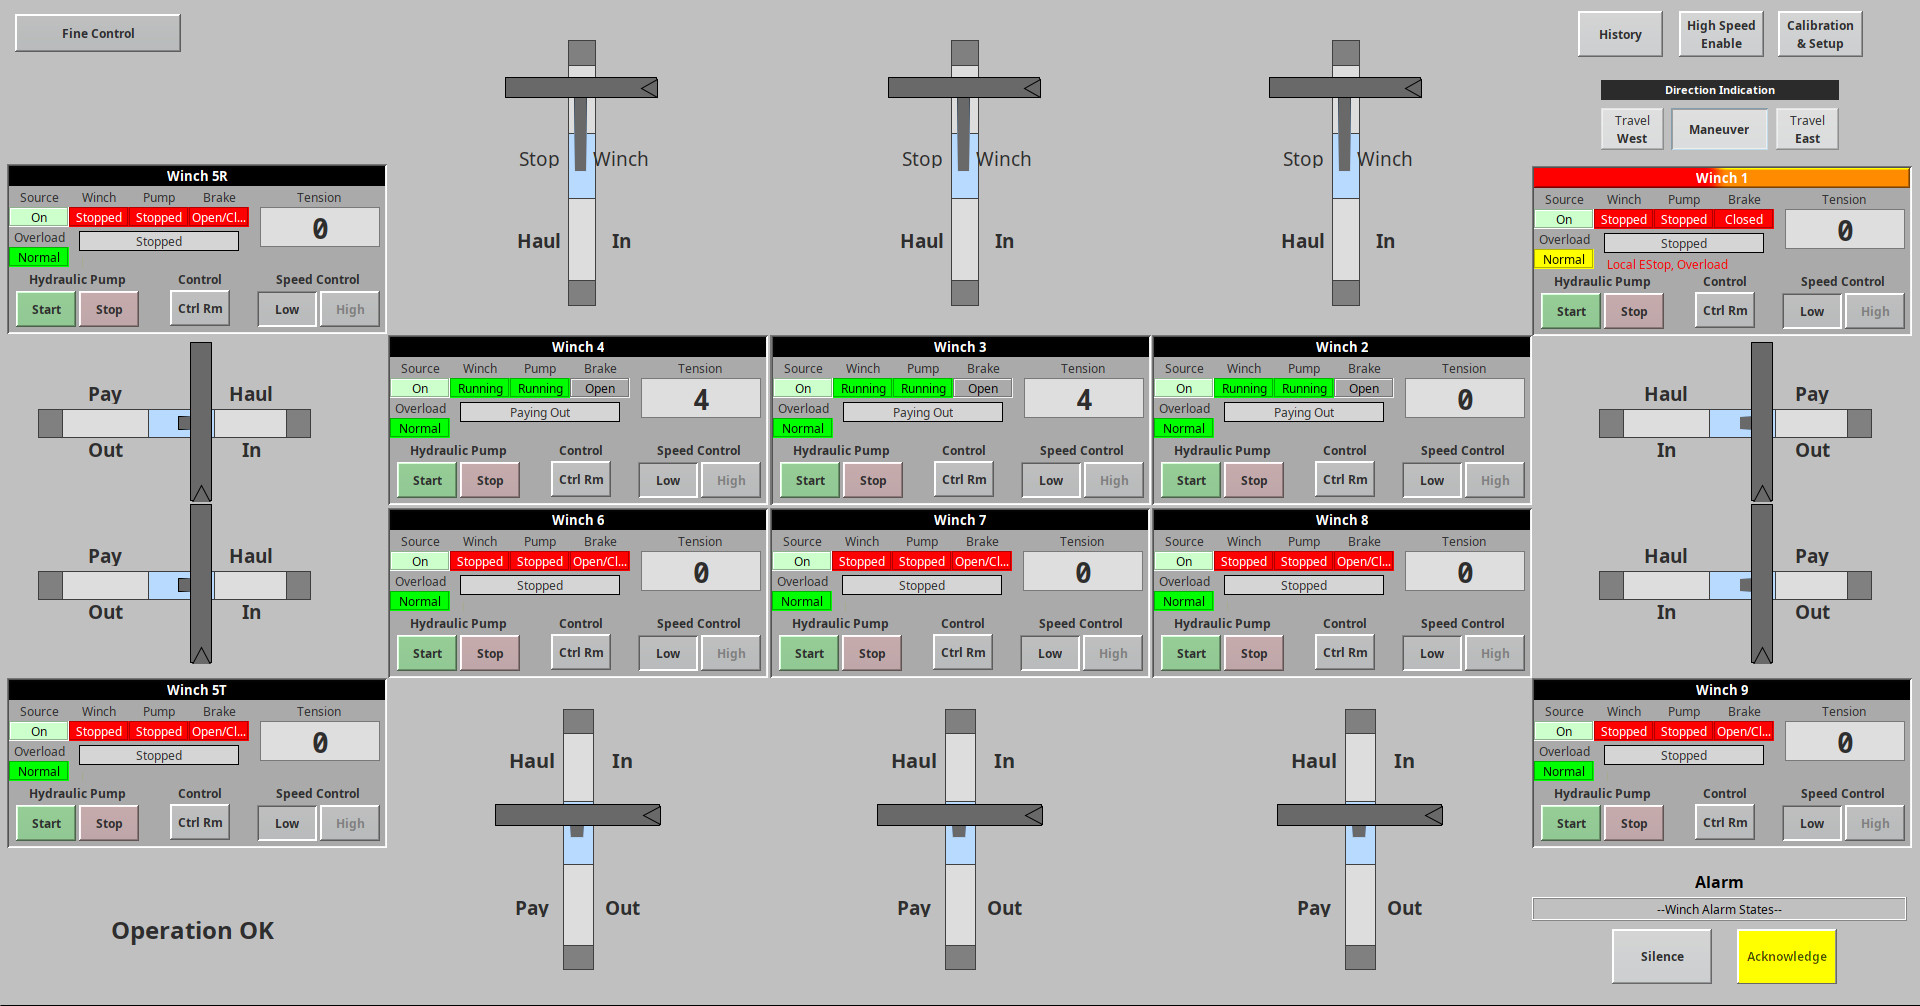
As a minimum, the winch screens show the status of the winch, the tensions, and other information related to the safety of the equipment.
It is also common to provide a means of control, typically including selectors that allow groups of winches to be operated together. This may be touch screen control, or it may have an associated physical joystick or joysticks.
Finally, the APS module may have a means to automatically position the dock. To accomplish this, specific types of hardware sensors are required. Depending on the pulling medium this can change drastically. If there is interest in this, please contact us directly.
|